Founded in Japan, 2023
Founded in Nagano in June 2023, as the SI wave was gathering pace, we are among the early humanoid robotics startups in Japan. Today we are based in Kawasaki, Kanagawa.

SI = Superintelligence
BorgRoid is the name we coined for the robots of the future: living with people, powered by SI. Founded in Nagano in 2023, we are a Japanese robotics company working toward general-purpose humanoids.
Founded in Nagano in June 2023, as the SI wave was gathering pace, we are among the early humanoid robotics startups in Japan. Today we are based in Kawasaki, Kanagawa.
Not a machine built for a single task, but a general-purpose humanoid robot that can work alongside people in every part of life and work.
Joint modules define a humanoid's performance. We help you select, quote and procure them — supporting the first step of your robot development.
Frameless torque motor. Also available on its own.
Planetary (DZ) / G4 (SJB) / strain wave (SJC).
Built-in 19-bit dual magnetic encoder. EtherCAT / CANopen / RS485.
Three series to choose from by size, torque and control interface.

DZA52, 60, 70 and 96. Planetary gear type, selectable by mounting conditions.

Outer diameter 80, 90 and 110 mm, with an integrated G4 reducer.

Outer diameter 52–110 mm. Strain wave gearing for high reduction ratios.
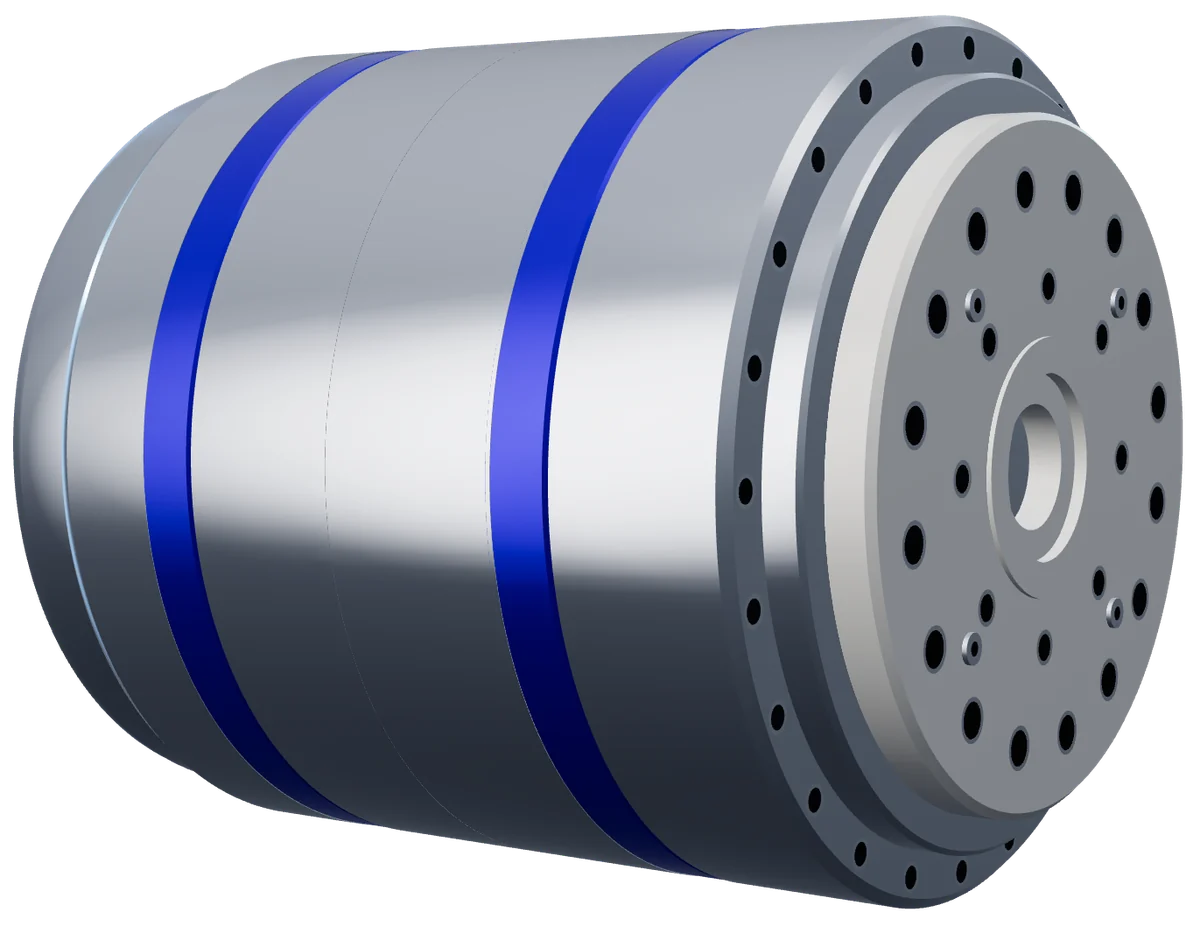
Reference images: catalog, April 2026 edition. Appearance varies by model.
One model per size (catalog values). Please confirm the latest specifications before adoption.
| Model | Voltage | Rated torque | Peak torque | Ratio | Mass |
|---|---|---|---|---|---|
| DZA52-10D14A-001 | 48 V DC | 6.6 N·m | 12 N·m | 1:36 | 400 g |
| DZA60-08D14A-001 | 48 V DC | 9.6 N·m | 25 N·m | 1:36 | 500 g |
| DZA70-10C14A-001 | 36 V DC | 4.5 N·m | 13.5 N·m | 1:9 | 370 g |
| DZA96-11C14A-001 | 36 V DC | 14.5 N·m | 43.5 N·m | 1:9 | 550 g |
Interface: CAN. Peak torque is not a continuous rating.
| Model | Reducer | Outer dia. | Voltage | Rated torque | Rated speed |
|---|---|---|---|---|---|
| SJB80W-8D19A | G4 | 80 mm | 48 V DC | 13.27 N·m | 77 rpm |
| SJB90W-13D19A | G4 | 90 mm | 48 V DC | 30.93 N·m | 77 rpm |
| SJB110W-26D19A | G4 | 110 mm | 48 V DC | 117.31 N·m | 59 rpm |
| SJC70W-08D19A-101 | Strain wave | 70 mm | 48 V DC | 12.50 N·m | 30 rpm |
Interfaces: EtherCAT / CANopen / RS485. Built-in 19-bit dual magnetic encoder.
The same joint modules we use on our own path to a general-purpose humanoid. Specifications, lead times and feasibility are confirmed directly with the production floor.
Founded June 2023 · Kawasaki, Kanagawa
Start from your application and requirements, even without a model number. From evaluation quantities to volume production.
TEL +81-44-789-9880 · 9:30–17:30 JST, Mon–Fri
Member since January 2025. Selection aligned with your interface (EtherCAT / CANopen / RS485 / CAN) and control scheme.
Source: BorgRoid news, January 22, 2025
Where it is used, torque and speed, outer diameter, power and interface.
Candidate products, quantities, lead times and quotation terms.
From evaluation units to supply terms for volume production.
No model number yet? Start from your application and requirements.
Phone +81-44-789-9880 (9:30–17:30 JST, Mon–Fri)
Email info@borgroid.co.jp